Updated
news
publications
- IROS 2026NoContactNoWorries: Estimating Contact through Vision and Proprioception for In-Hand Dexterous ManipulationIn IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
A transformer fusing RGB-D observations with proprioception estimates binary hand-object contact states, replacing hardware tactile sensors with a learned pseudo-tactile signal. The predicted contacts drive downstream RL for in-hand object reorientation, generalize zero-shot to novel objects, and are validated on a real robot.
- Under ReviewAnyViewDex: View-Invariant Dexterous Manipulation from RGB Observations* Equal contribution2026
Visuomotor dexterous policies are notoriously brittle to camera viewpoint shifts; regularizing a 2D monocular backbone with privileged 3D geometric supervision from simulation resolves this without depth sensors at test time. Zero-shot sim-to-real transfer on an xArm7 with a 16-DoF LEAP Hand achieves 76.7% grasping success across eight unseen objects and six uncalibrated viewpoints.
-
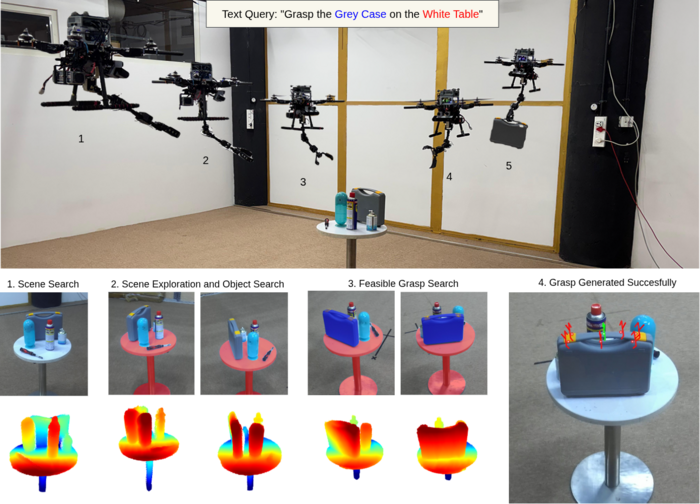 IROS 2026AeroGrab: A Unified Framework for Aerial Grasping in Cluttered EnvironmentsIn IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
An end-to-end aerial grasping pipeline for cluttered environments: a language instruction selects the target, the platform actively repositions for better views, a grasp network proposes 6-DoF candidates per view, and collision-aware feasibility checking selects the one to execute. Validated on a real aerial manipulator in cluttered scenes.
stepping stones
DextrAH-RGB on xArm7 + LEAP Hand
Ported the DextrAH-RGB dexterous grasping pipeline to our xArm7 and LEAP Hand, including the geometric fabrics controller, a ros2_control interface for the LEAP Hand, and policy changes for our setup so we can retrain it for our own tasks. Containerised, with Isaac Sim and Gazebo digital twins, and runs the policy at 30 Hz with plenty of headroom.
Dense Tactile In-Hand Manipulation
Ongoing work on how dexterous policies can use dense binary contact information over the hand, starting with dexterous grasping and also in-hand rotation with the LEAP Hand.
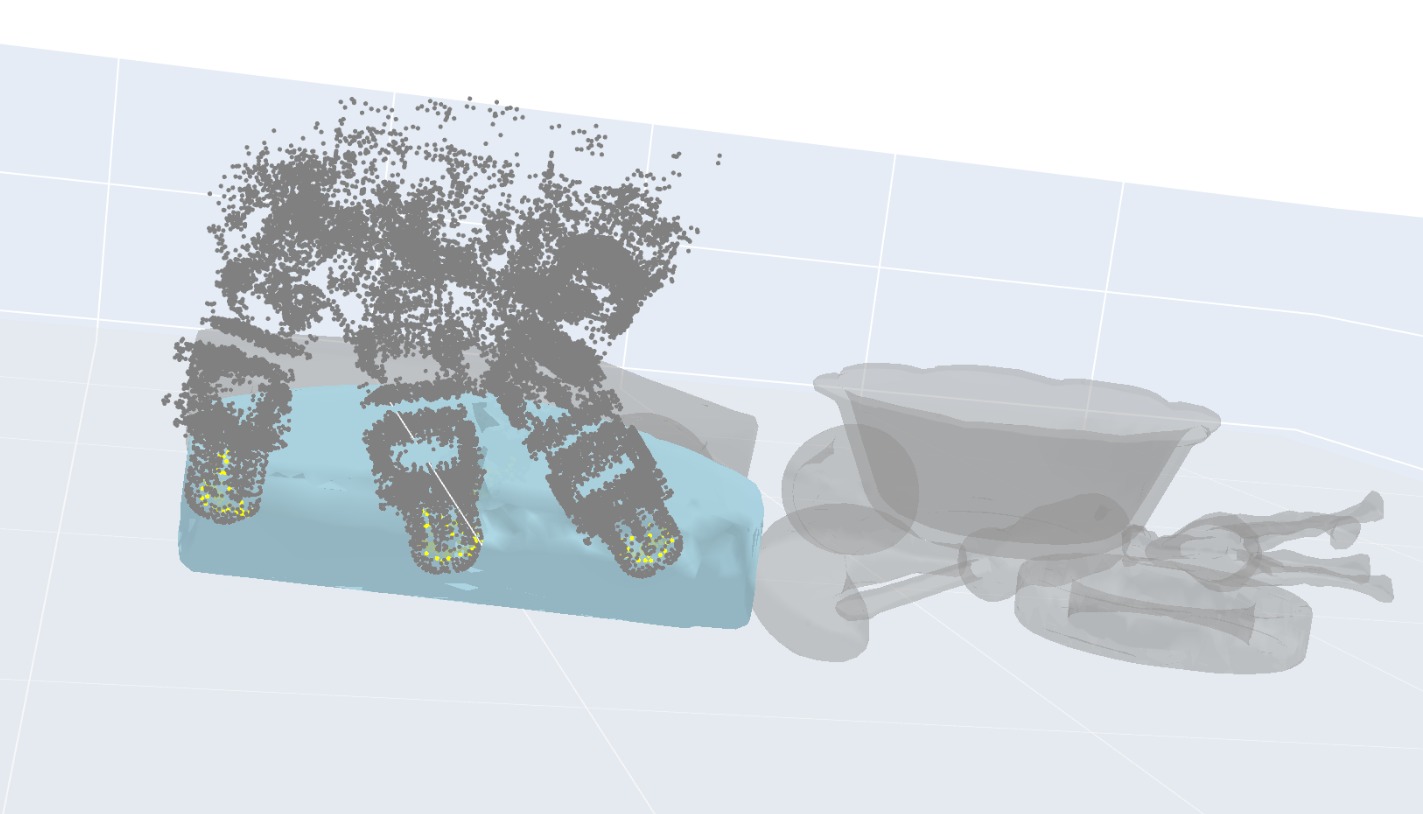
Hand-Object Contact Dataset Generation
Large-scale generation of hand-object contact labels. The first version recorded contacts with Isaac Sim's contact API while the hand actively manipulated objects; this was later updated to better techniques.
LEAP Hand with Custom Tactile Fingertips
Fitted the LEAP Hand's fingertips with FSR sensors that report binary contact, and extended its proprioception-only policy to use these readings. Deployed zero-shot from simulation for in-hand rotation.
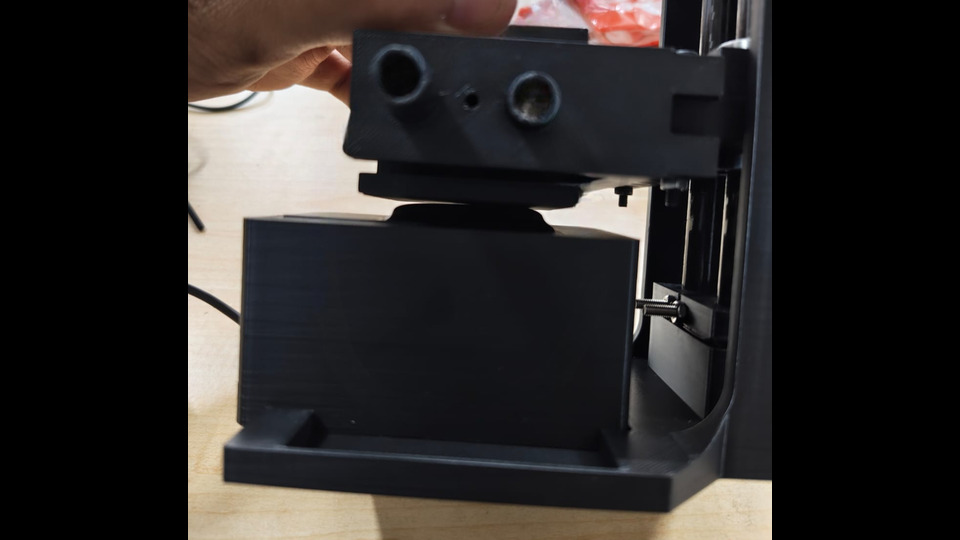
Vision-Based Tactile Sensor Calibration
Vision-based tactile sensors drift as their gel surface wears over time. Tried out methods for calibrating their shear readings to keep measurements consistent.
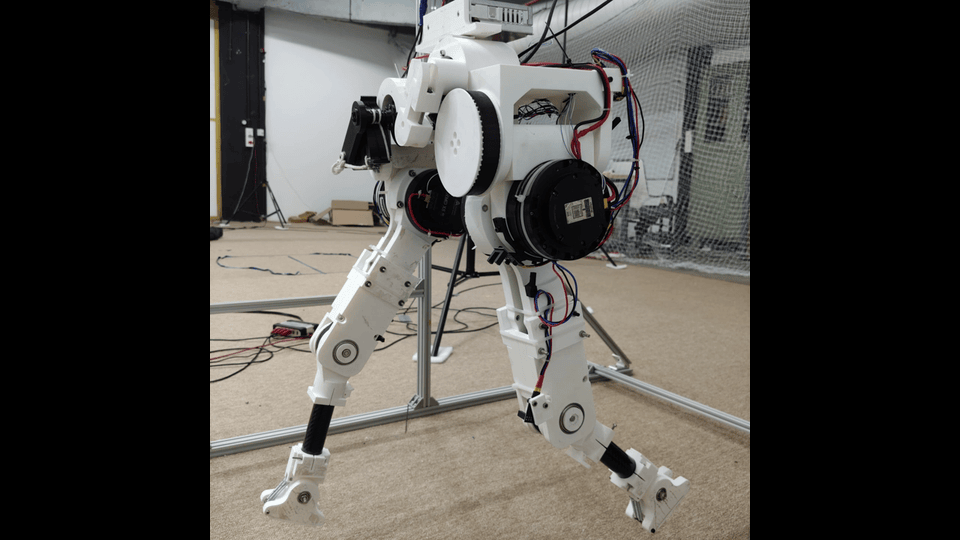
Bipedal Robot Hardware Bring-Up
Early hardware bring-up of a bipedal robot in our lab, covering low-level motor control and the ros2_control software packages, so that colleagues could build their research on it. The platform was later taken forward by others in the lab.
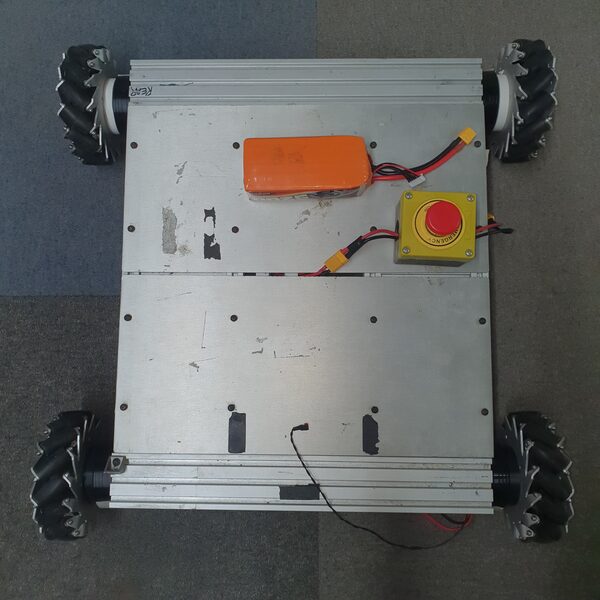
MPCHoloNavigation
Model-predictive-control holonomic navigation in ROS 2, with SLAM Toolbox localisation and Nav2 integration. Course project, Robotics: Planning and Navigation, IIIT Hyderabad.
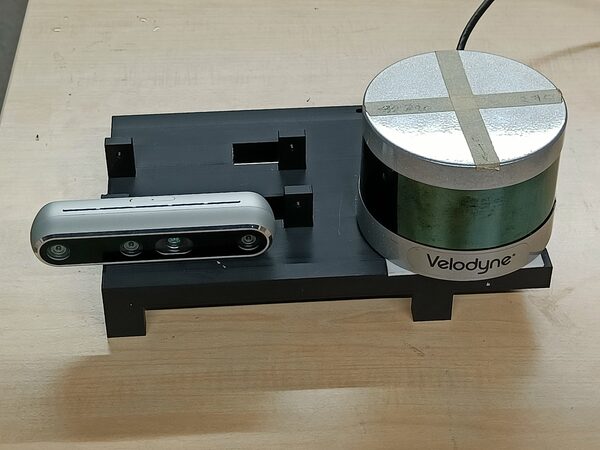
LiDAR_Camera_Calibration
Extrinsic and intrinsic LiDAR-camera calibration from rosbag data and checkerboard images, using Zhang's method for intrinsics. Course project, Mobile Robotics, IIIT Hyderabad.
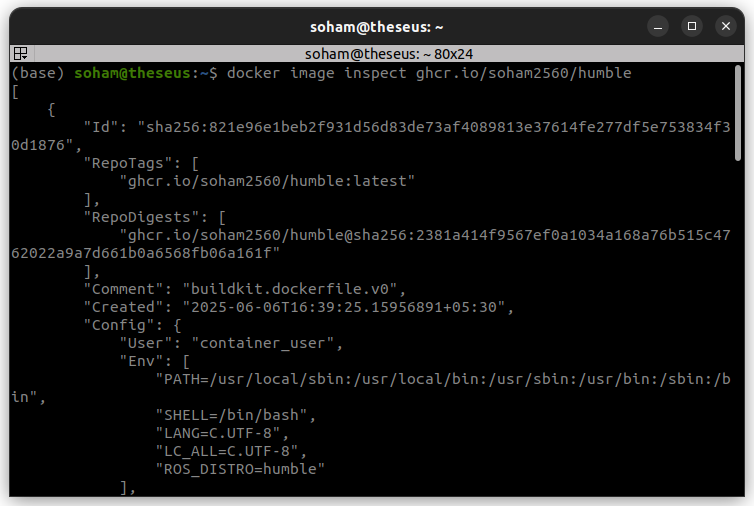
DockerForROS2Development
Pre-built Dev Container images for ROS 2 (Humble, Iron) and ROS 1 (Noetic), with optional Gazebo, published on GHCR.
experience
- Hardware-diagnostics support for
ros2_control: a standardised health and fault-reporting API, new ROS messages (HardwareStatus,HardwareDeviceStatus), a unified Actuator/Sensor/System interface, and default diagnostic nodes with CLI tooling. Mentors: Dr. Bence Magyar, Sai Kishor Kothakota.
- Built an in-house collaborative robot arm and an end-to-end pipeline for testing custom controllers on hardware, supporting research on adaptive and robust control.
education
awards
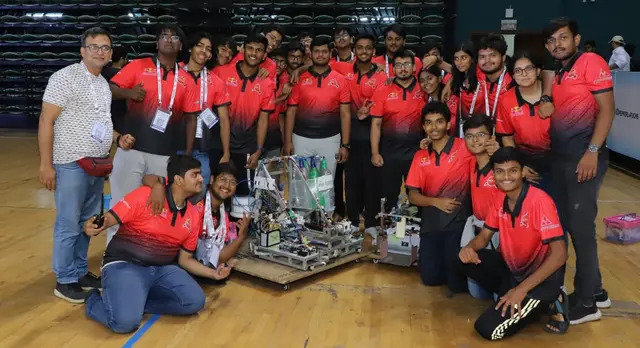
- Winner (2020), representing India at the international final; ranked 2nd (2023) and 4th (2022) nationally among 150+ teams.
- Led a team designing and building complete competition robots from scratch each season across mechanical design, custom electronics, firmware, motor control and autonomy; built an in-house integrated actuator matching commercial specs at ~half the cost, a wheeled-odometry module (<4% error), and ROS 2 / Nav2 autonomy on register-level AVR/TM4C firmware.
Watch the robots (2 videos)
teaching
- Mobile Robotics (CS7.503)Instructor: Prof. K. Madhava Krishna
- Robotics: Planning and Navigation (EC4.403)Instructor: Prof. K. Madhava Krishna
- Systems Thinking (EC5.202) OngoingInstructor: Prof. Spandan Roy
- Perception & Planning for Aerial Vehicles CourseInstructors: Prof. K. Madhava Krishna, Prof. Harikumar Kandath, Prof. Antony Thomas